
Collaborative Robots for Machine Tending, Assembly and Packing
Cobots from Universal Robots, FANUC and Yaskawa, from 3 kg to 30 kg payload, supplied and integrated as working cells: gripper, vision, safety and PLC interface included. Our engineers help you size the arm and the risk assessment before you buy.
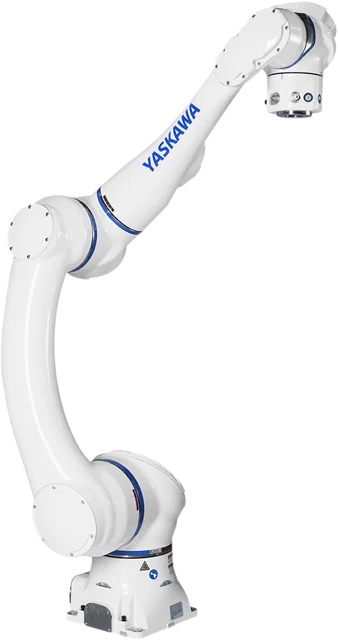
A cobot chosen on the arm's payload alone often fails on site: the gripper eats the payload margin, the reach misses the far pick point, or the risk assessment shows the task needs guarding after all.
Types of collaborative robots
Universal Robots e-Series
Six-axis arms from 3 kg to 16 kg payload and 500 mm to 1300 mm reach, programmed from a tablet-style teach pendant or by hand-guiding. The common choice for CNC tending, screwdriving and inspection.
Models: UR3e · UR5e · UR7e · UR10e · UR12e · UR16e
Universal Robots UR Series
The newer UR arms extend the range to 30 kg payload and up to 1750 mm reach, for heavier parts, end-of-line packing and light palletising.
Models: UR8 Long · UR15 · UR18 · UR20 · UR30
FANUC CRX
Cobots from 5 kg to 30 kg payload and 994 mm to 1756 mm reach, with positional accuracy of ±0.04 mm. Food Grade and Paint variants are available for food handling and coating tasks.
Models: CRX-5iA · CRX-10iA · CRX-10iA/L · CRX-20iA/L Food Grade · CRX-30iA Food Grade
Yaskawa HC
Cobots from 10 kg to 30 kg payload with reach up to 1900 mm, suited to longer-reach handling and heavier cartons.
Models: HC10DTP · HC10DTFP · NHC12 · HC20DTP · HC20SDTP · HC30PL
What to specify
| Parameter | What to check |
|---|---|
| Payload | Add the gripper, any tool changer and the heaviest part, then keep a margin. If the total is above about 30 kg, look at an industrial robot instead. |
| Reach | Measure to the farthest pick and place point, including the gripper length and any approach move into a machine or carton. |
| Risk assessment | Fence-free operation depends on a risk assessment to ISO 10218 and ISO/TS 15066 covering the gripper, the part and the process, not just the arm. Sharp edges, hot parts or welding may still need guarding or scanners. |
| Cycle time | A cobot slows down when a person enters the shared space. If the task must run at full speed every cycle, compare it against a guarded industrial robot. |
| Environment | Washdown, food contact or coating work call for the matching variant, such as the CRX Food Grade or Paint models. |
| Interfaces | List the machine signals, PLC, vision and gripper the cobot must work with, so the cell is engineered as one system. |
26 models in our range
Universal Robots e-Series 6
Universal Robots UR10e
Collaborative robot arm, 12.5 kg payload, 1300 mm reach. Rajdeep's most-deployed UR model for automotive pick-and-place and machine tending
View Details →
Universal Robots UR12e
Universal Robots 6-axis collaborative robot with 12.5 kg payload, 1300 mm reach, positional accuracy ±0.05 mm.
View Details →
Universal Robots UR16e
Universal Robots 6-axis collaborative robot with 16 kg payload, 900 mm reach, positional accuracy ±0.05 mm.
View Details →
Universal Robots UR3e
Universal Robots 6-axis collaborative robot with 3 kg payload, 500 mm reach, positional accuracy ±0.03 mm.
View Details →Universal Robots UR5e
Collaborative robot arm, 5 kg payload, 850 mm reach. Rajdeep's deployed UR model for lighter automotive/assembly tasks
View Details →
Universal Robots UR7e
Universal Robots 6-axis collaborative robot with 7.5 kg payload, 850 mm reach, positional accuracy ±0.03 mm.
View Details →Universal Robots UR Series 5

Universal Robots UR15
Universal Robots 6-axis collaborative robot with 15 kg payload, 1300 mm reach, positional accuracy ±0.05 mm.
View Details →
Universal Robots UR18
Universal Robots 6-axis collaborative robot with 18 kg payload, 950 mm reach, positional accuracy ±0.05 mm.
View Details →
Universal Robots UR20
Universal Robots 6-axis collaborative robot with 20 kg payload, 1750 mm reach, positional accuracy ±0.05 mm.
View Details →
Universal Robots UR30
Universal Robots 6-axis collaborative robot with 30 kg payload, 1300 mm reach, positional accuracy ±0.10 mm.
View Details →
UR8 Long
Universal Robots 6-axis collaborative robot with 8 kg payload, 1750 mm reach, positional accuracy ±0.05 mm.
View Details →FANUC CRX 9

Fanuc CRX-10iA
FANUC 6-axis collaborative robot with 10 kg payload, 1249 mm reach, positional accuracy ±0.04 mm (typical).
View Details →
CRX-10iA Food Grade
FANUC 6-axis collaborative robot with 10 kg payload, 1249 mm reach, positional accuracy ±0.04 mm.
View Details →
Fanuc CRX-10iA/L
FANUC 6-axis collaborative robot with 10 kg payload, 1418 mm reach, positional accuracy ±0.04 mm.
View Details →
CRX-10iA/L Food Grade
FANUC 6-axis collaborative robot with 10 kg payload, 1418 mm reach, positional accuracy ±0.04 mm.
View Details →
CRX-10iA/L Paint
FANUC 6-axis collaborative robot with 10 kg payload, 1418 mm reach, positional accuracy ±0.04 mm.
View Details →
CRX-20iA/L Food Grade
FANUC 6-axis collaborative robot with 20 kg payload, 1418 mm reach, positional accuracy ±0.04 mm.
View Details →
CRX-30iA Food Grade
FANUC 6-axis collaborative robot with 30 kg payload, 1756 mm reach, positional accuracy ±0.04 mm.
View Details →
Fanuc CRX-5iA
FANUC 6-axis collaborative robot with 5 kg payload, 994 mm reach, positional accuracy ±0.04 mm.
View Details →
CRX-5iA Food Grade
FANUC 6-axis collaborative robot with 5 kg payload, 994 mm reach, positional accuracy ±0.04 mm.
View Details →Yaskawa HC 6

Yaskawa HC10DTFP
Yaskawa 6-axis collaborative robot with 10 kg payload, 1379 mm reach, positional accuracy ±0.05 mm.
View Details →
Yaskawa HC10DTP
Yaskawa 6-axis collaborative robot with 10 kg payload, 1379 mm reach, positional accuracy ±0.05 mm.
View Details →
Yaskawa HC20DTP
Yaskawa 6-axis collaborative robot with 20 kg payload, 1900 mm reach, positional accuracy ±0.05 mm.
View Details →
Yaskawa HC20SDTP
Yaskawa 6-axis collaborative robot with 20 kg payload, 1412 mm reach, positional accuracy ±0.05 mm.
View Details →
Yaskawa HC30PL
Yaskawa 6-axis collaborative robot with 30 kg payload, 1700 mm reach, positional accuracy ±0.05 mm.
View Details →
Yaskawa NHC12
Yaskawa 6-axis collaborative robot with 12 kg payload, 1410 mm reach, positional accuracy ±0.05 mm.
View Details →Where they're used
CNC & VMC machine tending
Loading and unloading lathes and machining centres, including door and chuck signals.
Assembly & screwdriving
Fastening, pressing and part insertion next to operators.
End-of-line packing
Case packing and light palletising of cartons.
Inspection & gauging
Presenting parts to cameras and gauges with repeatable positioning.
Dispensing & finishing
Gluing, sealing, deburring and polishing with force-sensitive tooling.
Food & pharma handling
Food Grade variants for primary and secondary handling.
Common questions
Does a cobot need a safety fence?
Not always. Cobots use power and force limiting, and with a risk assessment to ISO 10218 and ISO/TS 15066 many tasks run without a full fence. The assessment must include the gripper, the part and the process: a sharp or hot part, or a welding torch, can still require guarding or safety scanners.
What payload cobot do I need?
Add the weight of the gripper and the heaviest part, and keep a margin for the part's offset from the tool flange. For example, a 6 kg part on a 3 kg gripper already needs a 10 kg class arm such as the UR10e or CRX-10iA rather than a 7 kg one.
Should I choose a cobot or an industrial robot?
Choose a cobot when an operator shares the workspace, floor space is tight or the product mix changes often. Choose an industrial robot in a guarded cell for loads above about 30 kg including the gripper, short cycle times or one part running at volume for years. Our guide on cobots versus industrial robots covers this in detail.
Universal Robots, FANUC CRX or Yaskawa HC: which one?
All three cover similar payload ranges. The choice usually comes down to reach, environment (Food Grade or Paint variants), and which robot brand your plant already maintains and programs. Share the task and we will recommend a model.
Do you supply only the arm or the complete cell?
Both. Along with the arm we engineer the gripper, vision, safety devices and PLC integration, and take the cell through build, programming, trials, installation and operator training.
- Established
- 1994
- Quality system
- ISO 9001:2015
- Offices
- 8 across India
- Support
- In-house application engineers


Planning a cobot application?
Tell us the part weight, the gripper you have in mind, the reach and the cycle time, and whether people work alongside. We'll recommend a cobot and propose the cell.